Video: Feather star-inspired robot moves underwater with just two actuators
Researchers at North Carolina State University have developed a soft underwater robot inspired by feather...
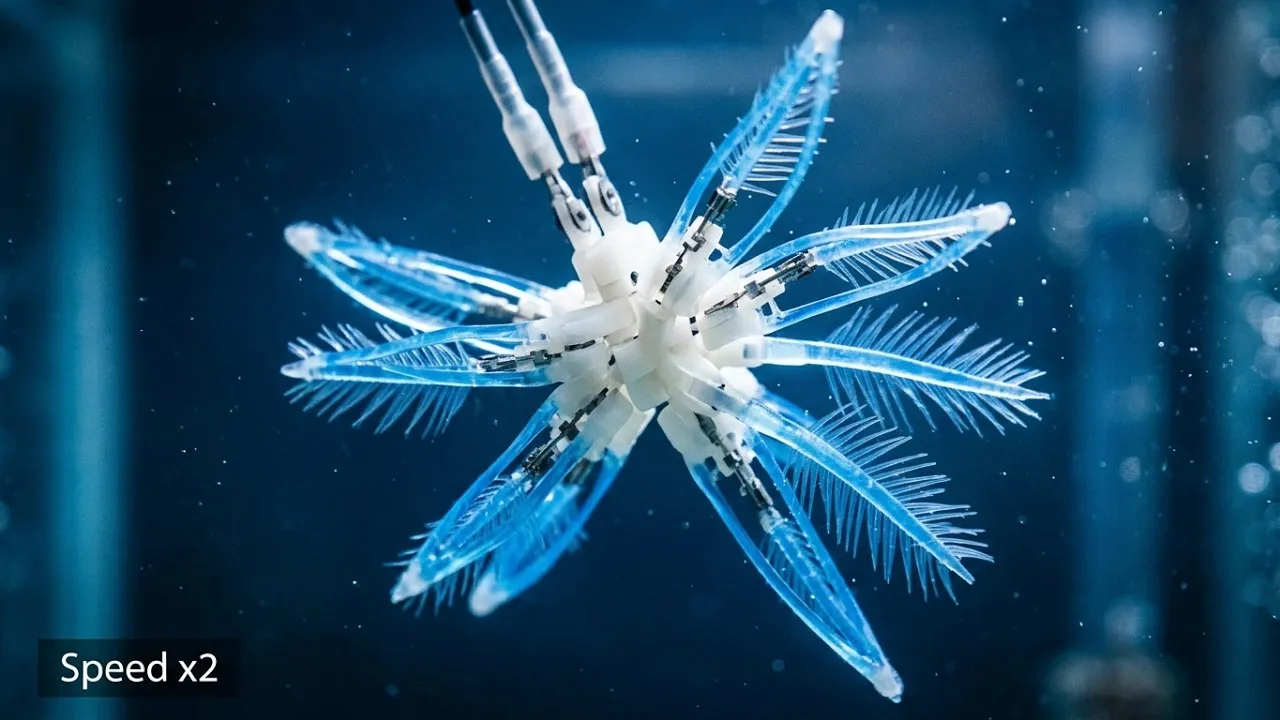
Researchers at North Carolina State University have developed a soft underwater robot inspired by feather stars, a type of marine invertebrate.
The robot can move in three dimensions, including forward and backward, up and down, and rotation around its axis.
It achieves this range of motion using only two actuators, compared with the six typically required for similar three-dimensional movement.
The design uses “mechanical intelligence,” relying on the robot’s structure and interactions with water to reduce the amount of control input needed.
Feather star robot
Researchers at North Carolina State University have developed a soft underwater robot that achieves three-dimensional movement using just two actuators, reducing the mechanical complexity normally required for this level of maneuverability.
Inspired by feather stars, marine invertebrates that can move in different directions and hover by coordinating their limbs, the robot uses four elastic wings arranged around a central disk. The wings are monostable, meaning they can bend under actuation but naturally return to their original position when the force is removed. This mechanical design allows the robot to generate several types of motion without requiring a separate actuator for each direction.
According to the NCSU team, the system is based on the principle of “mechanical intelligence,” in which a robot’s physical structure helps determine its behavior and reduces the amount of control input required from computers or human operators. Conventional systems capable of comparable three-dimensional movement would typically require at least six actuators.
“One exciting aspect of this work is that it demonstrates how we can create robotic devices with an incredible range of motion using a minimum number of actuators, by taking advantage of intelligent design techniques,” said Jie Yin, corresponding author of the study and a professor of mechanical and aerospace engineering at NCSU, in a statement.
Switches movement modes
The robot’s two actuators are housed in its central disk and control all four wings. When both actuators are activated, the wings snap downward. Once the actuators are switched off, the elastic wings return upward. Repeating this cycle rapidly makes the robot flap its wings and move upward through the water. When the wings flap more slowly, the robot can maintain its position and hover, a movement the researchers call “jellyfish mode.”
The same hardware can produce horizontal movement by changing how the actuators are controlled. Activating only one actuator causes a wing to flutter like a tailfin, pushing the robot forward or backward. The researchers refer to this as “fish mode.”
The robot can also rotate around its central axis. By rapidly alternating between the two actuators, the researchers generate asymmetric wing movements that cause the robot to spin. This “rotor mode” provides directional control, allowing the robot to steer while underwater.
Together, the three movement modes give the soft robot control over vertical, horizontal, and rotational motion. The researchers demonstrated the system exploring underwater environments with a camera and lifting objects either individually or in coordination with other robots.
The design builds on earlier work by the team involving a manta ray-inspired aquatic robot that could move rapidly through water but lacked comparable three-dimensional maneuverability. Instead of adding more motors and complex mechanisms, the researchers sought to obtain additional movement capabilities through the robot’s physical structure.
The team noted that the compact design could provide a platform for underwater robotic applications where maneuverability and mechanical simplicity are important. Future work will focus on developing a fully wireless version and exploring potential applications in collaboration with researchers from other fields.
Related articles
Thread-thin FiberMotor slides like telescope to power soft robots and wearables
Engineers at EPFL in Switzerland have built a flexible motor that looks like a thread...
After Navier-Stokes, OpenAI’s 377 math results leave experts demanding a voice
OpenAI has published more than 370 new mathematical results, stunning mathematicians and igniting a debate...
US backs $1.5B conditional loan for chips used in drones, radar, missile defense
The US Department of War has offered semiconductor manufacturer Wolfspeed up to $1.5 billion in...
World’s first fleet-capable drilling robot hits 10x speed with 99% accuracy
A drilling robot built for data center construction has already punched more than 385,000 holes...
US microreactor that reached criticality in 150 days set for full-power test in 2027
A US-developed nuclear battery that achieved its first controlled chain reaction in roughly 150 days...
Nous Research raises $90 million at $1.5 billion valuation to take its open-source Hermes agent to businesses
Nous Research, developer of the open-source Hermes Agent, has raised a $90 million Series B led by Robot Ventures and is launching Hermes for Businesses, letting companies deploy customized AI agents while keeping their data private.