What happens when a drone loses signal? Here’s how its failsafes work
A drone losing its connection to the remote controller does not necessarily mean it will...
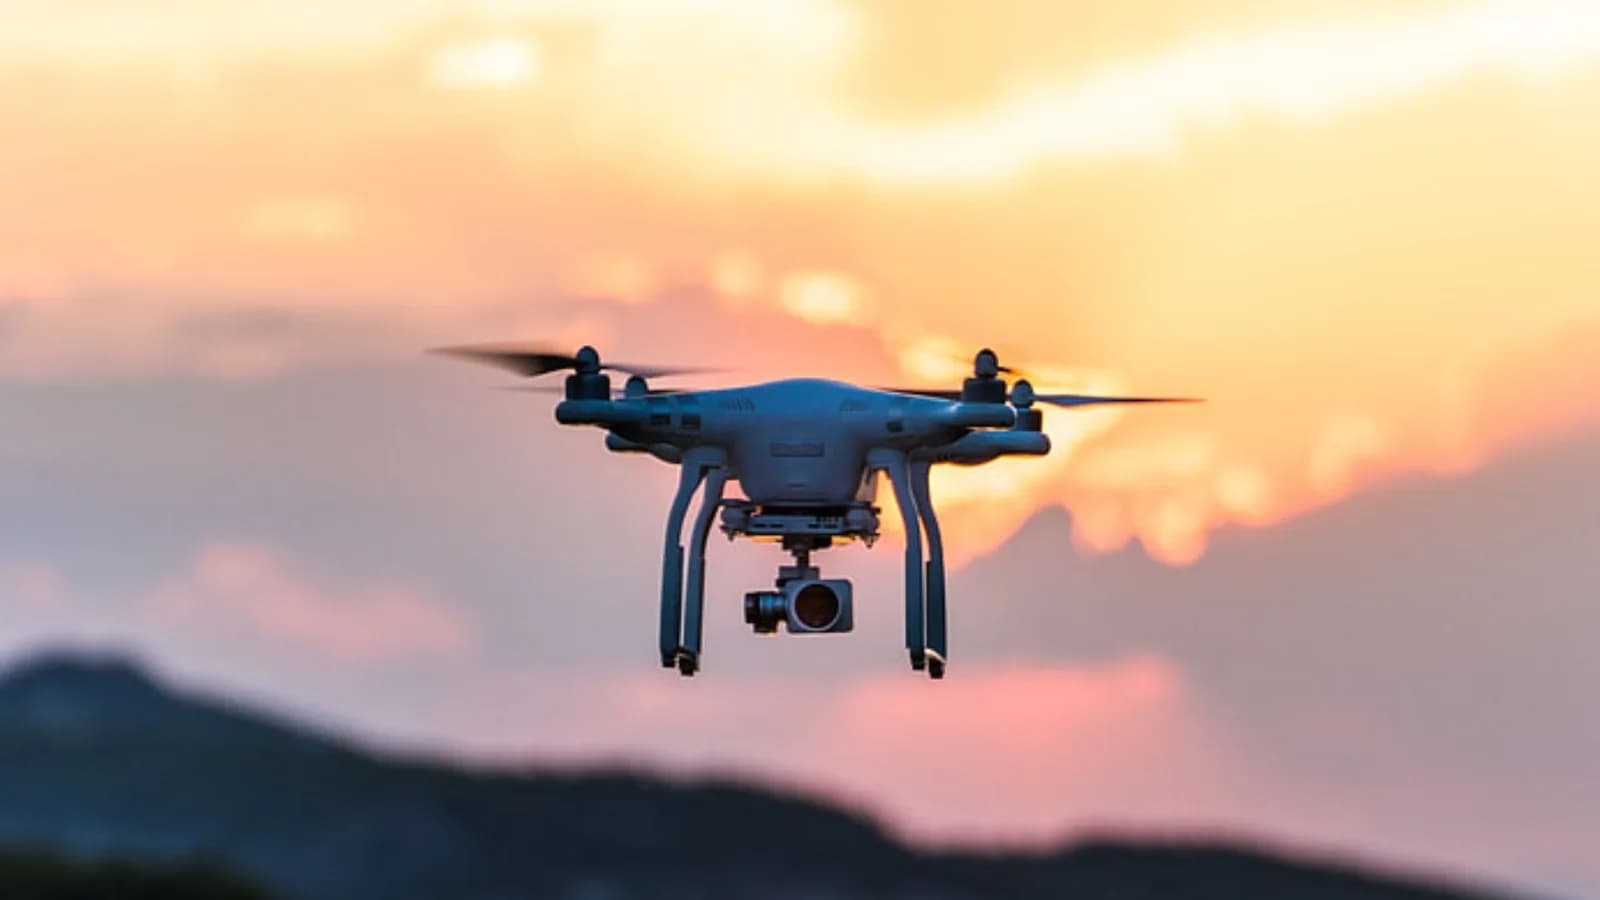
A drone losing its connection to the remote controller does not necessarily mean it will fall out of the sky. Depending on its configuration, it may hover in place, return to its launch point, or attempt to land automatically. But if the aircraft also loses access to reliable navigation data, the situation can become considerably more complicated.
What happens next depends on which connection has failed, what flight-control systems remain available, and how the drone has been programmed to respond.
Not all signal losses are the same
Most consumer drones rely on several communication and navigation systems working together. The most obvious is the command-and-control link between the aircraft and its remote controller. It carries the pilot’s instructions, such as changes in direction, altitude, and speed.
Many drones also transmit a live video feed and flight telemetry to the controller. These connections may experience interference or dropouts independently of the control link, meaning a pilot can sometimes lose the camera feed while retaining control of the aircraft.
Navigation is another matter. Drones commonly use Global Navigation Satellite Systems (GNSS), including GPS, alongside onboard sensors such as compasses, accelerometers and gyroscopes. These help the flight controller determine the aircraft’s position, orientation and movement.
Losing the controller connection does not automatically mean losing GPS navigation. Similarly, a drone can lose reliable GPS or compass information while remaining connected to its pilot.
What does a drone do when it loses connection?
Many modern drones have a failsafe feature called Return to Home (RTH). When the command link is lost for a configured period, the aircraft can use its stored home-point coordinates and navigation systems to fly back to its launch location.
Depending on the model and settings, the drone may first climb to a predetermined altitude to clear obstacles before following its return route. It can then descend and land automatically.
However, RTH is not the only possible response. Some drones can be configured to hover at their current position or land wherever they are if the connection is interrupted. The selected behavior often depends on the aircraft, its firmware, and the pilot’s settings.
For example, DJI drones provide configurable signal-loss responses on supported models. Open-source flight-control software such as ArduPilot also offers several failsafe actions, including Return to Launch, SmartRTL, and Land.
These safeguards are useful, but they are not guarantees. RTH requires the drone to have sufficient battery power, a valid home point, and the navigation information needed to follow its route. Obstacles, wind, sensor errors, or other system failures can prevent it from completing the maneuver safely.
What if the drone loses GPS?
A loss of GPS or other navigation data can be more challenging because the aircraft may no longer know its precise position.
Some multirotor drones switch to a flight mode commonly known as Attitude (ATTI) mode. In this mode, onboard sensors can help stabilize the aircraft’s orientation and maintain altitude, but it no longer automatically holds its position using GPS.
As a result, wind can push the drone away from its original location. The pilot must compensate manually using the controller, which can be difficult if the aircraft is far away or difficult to see.
A particularly dangerous situation occurs when a drone loses both its command link and the navigation data needed for RTH. It may be unable to receive instructions from the pilot or determine how to return to its launch point.
Real incidents show why failsafes are not foolproof
Two investigations by the UK’s Air Accidents Investigation Branch (AAIB) illustrate how navigation problems can turn into serious incidents.
In December 2019, a DJI Matrice M600 Pro surveying a construction site experienced a GPS-compass error. The aircraft switched from automated flight to ATTI mode, requiring manual control. Its pilot repeatedly attempted to activate RTH, but the drone continued drifting with the wind. It eventually struck the roof of a house before falling into the property’s garden. Investigators found that the aircraft had lost reliable heading information, preventing it from executing the return maneuver.
In another incident in November 2021, a DJI Phantom 4 Pro encountered magnetic interference shortly after takeoff in Rugby, England. The pilot received warnings that the aircraft had lost its heading reference and could no longer operate in its normal GPS-assisted mode. The command link subsequently failed, and the drone drifted approximately 630 meters over a populated area before landing in a tree.
Both incidents demonstrate that automated recovery depends on more than simply having a failsafe enabled.
Can pilots prevent a flyaway?
Pilots can reduce the risk by checking GPS reception and compass warnings before takeoff, selecting an appropriate RTH altitude and ensuring the home point has been recorded correctly. They should also monitor battery levels, weather conditions, and potential sources of electromagnetic interference.
Just as importantly, pilots should understand how their specific aircraft behaves when navigation or communication systems fail. Practicing manual flight and emergency procedures can make a significant difference if automated flight modes become unavailable.
A drone’s ability to recover from signal loss depends on the systems that remain operational. RTH and other failsafes can help an aircraft handle routine communication interruptions, but they cannot compensate for every combination of sensor failure, interference, and environmental conditions.
Get the latest news delivered to your inbox.
Related articles